Install Instructions
Tensile Mill Install
HMI ARM INSTALLATION
Use four M8 × 1.25 × 35mm hex-head screws

Mount Base of HMI Arm
Secure the HMI arm base to the cabinet using the four screws


Feed HMI Cables Through Cabinet and Arm


Insert and Tighten Arm Elbow
Install the horizontal arm (Cut to 13 1/2 inches), insert the internal cushion, then the elbow piece,
tighten screws,


Install vertical arm (Cut to 912 inches) and route Cables Into HMI Back Panel
Feed cables up into the rear panel opening of the HMI.


Step 7.6 — Before mounting HMI Rotate HMI to (Confirm Movement in the correct direction and not backwards)
Ensure the screen rotates freely in the correct direction. Install the keyboard and mouse tray along with the side handles.


M31 CONTROLLER INSTALLATION & WIRING
Step 1.1 — Mount the M31 Controller
Install the M31 Motion Controller in the bottom-left section of the control panel.
Ensure it is firmly mounted and positioned so that the J1–J18 terminals face outward for wiring access.


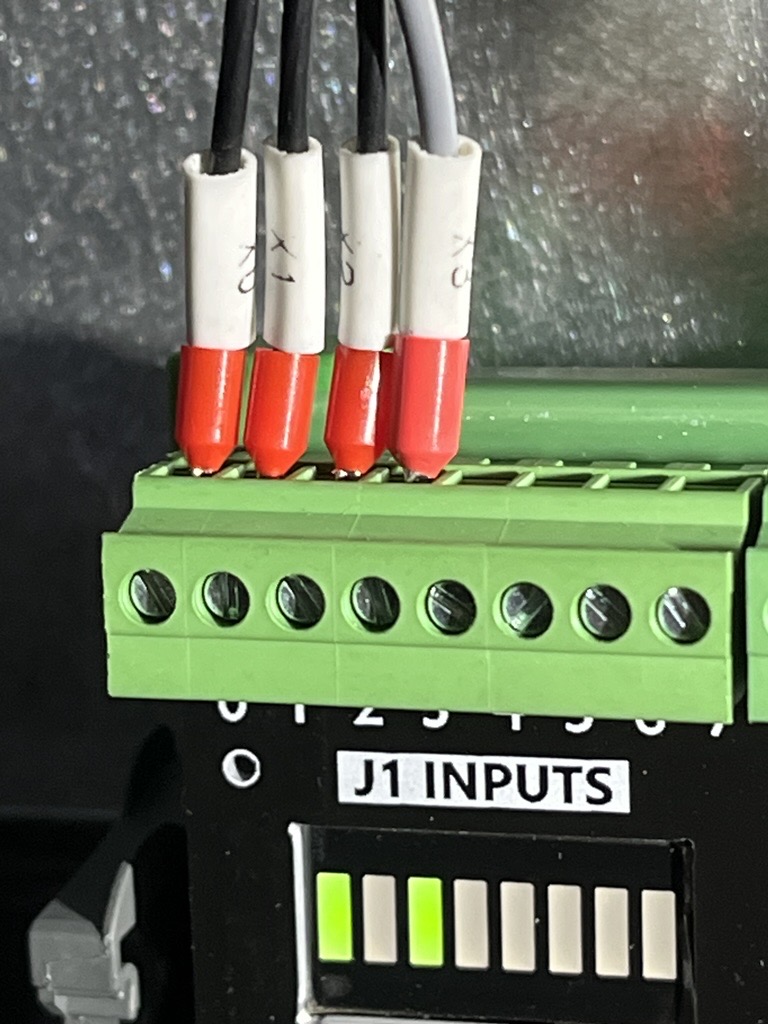
Step 1.2 — Install the X Limit Wire (X0) Into J1 Input 00
Step 1.3 — Install the Y Limit Wire (X1) Into J1 Input 01
Step 1.4 — Install the Z Limit Wire (X2) Into J1 Input 02
Step 1.5 — Install the Door Lock Input (X3) into J1 Input 03
SECTION 2 — EMERGENCY STOP WIRING
-
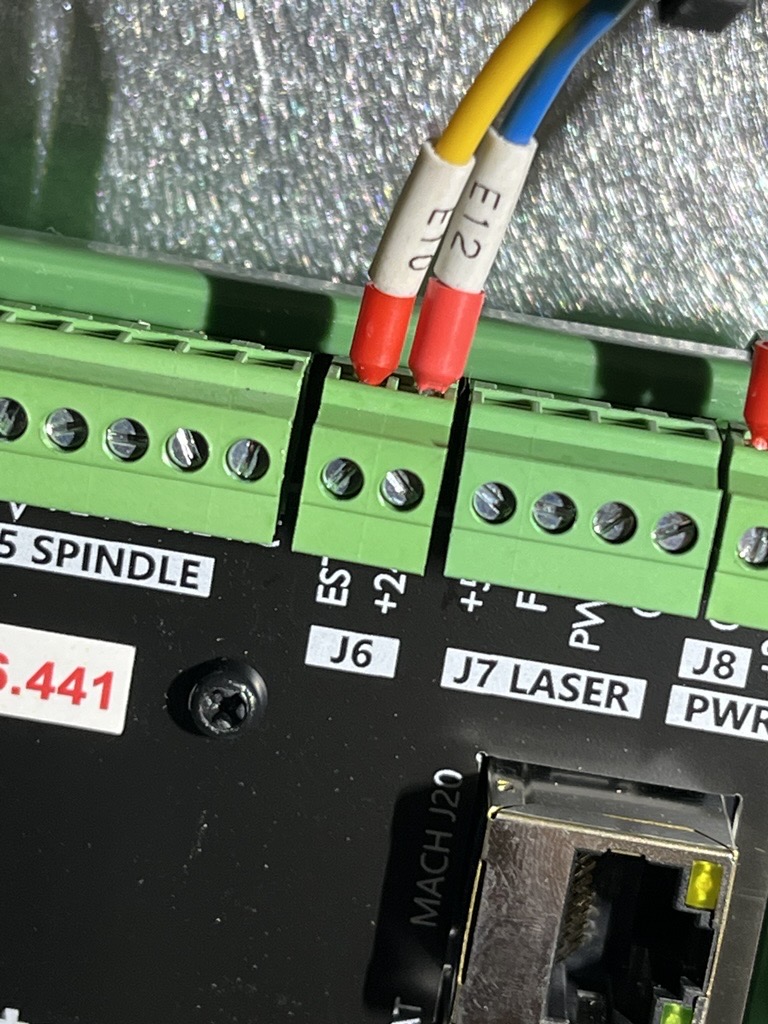
E10---ESTP
-
E12---+24V
SECTION 3 — POWER WIRING
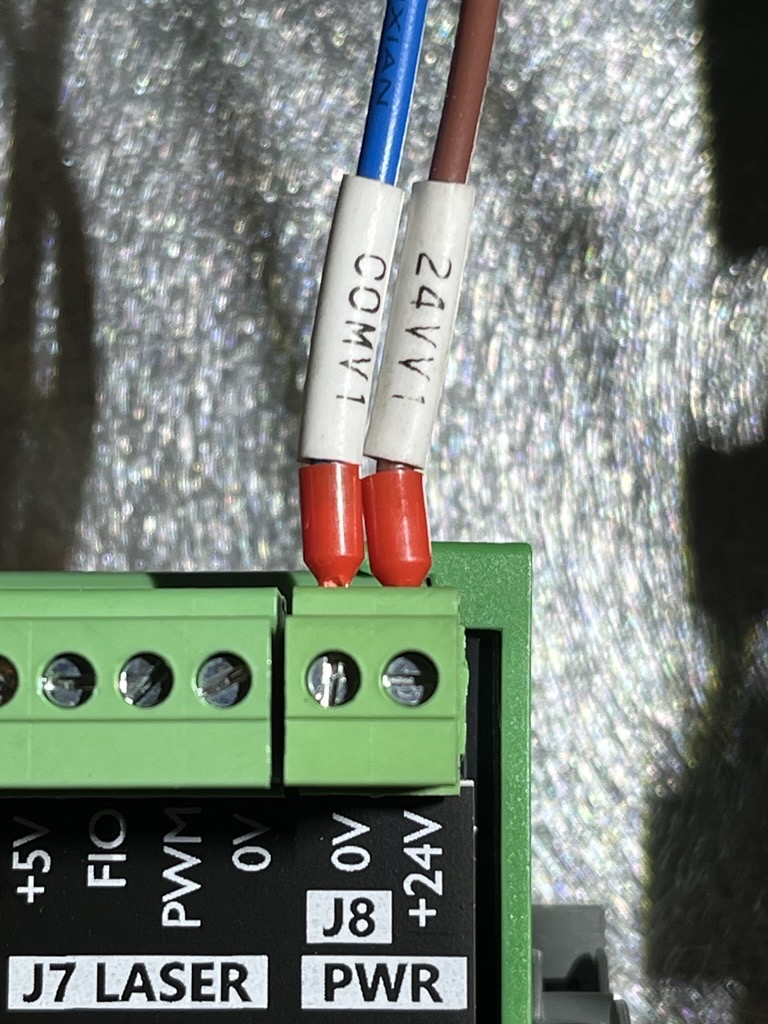
Connect the main 24V power to J8 Power:
-
24VV1---24V+
-
COMV1---0V
SECTION 4 — OUTPUTS AND RELAY WIRING
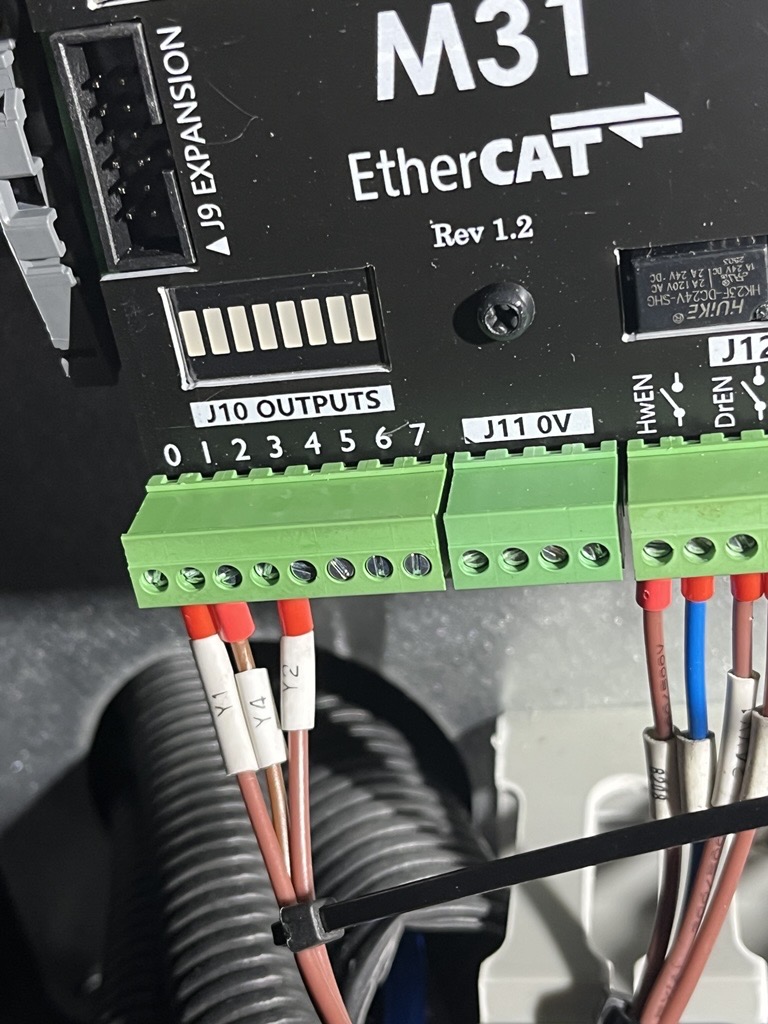
J10
Y1---J10-0
Y4---J10-1
Y2---J10-3
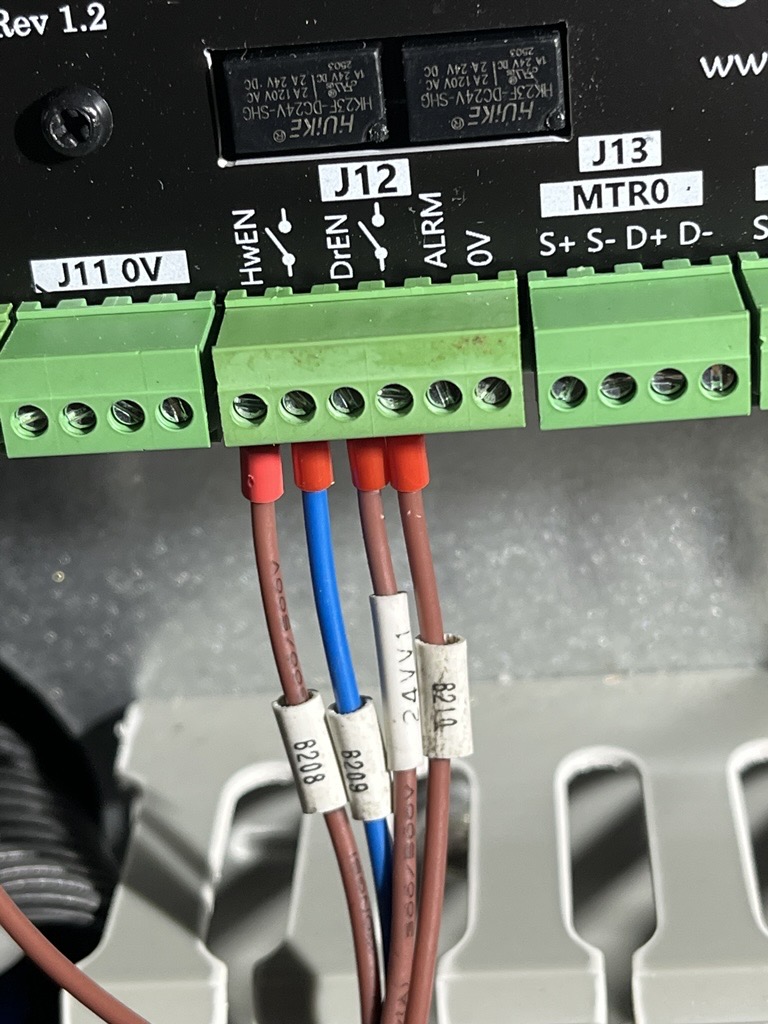
J12
- 8208----HwEN (J12-0)
- 8209----NO (J12-1)
- 24VV1--DrEN (J12-2)
- 8210----NO (J12-3)
SECTION 6 — ETHERCAT CONNECTION
Connect the EtherCAT cable from the servo drives into the EtherCAT port on the M31.

Connect MACHJ20 Cable to HMI
Plug the top Ethernet port labeled MACHJ20 into the HMI LAN port.

Control Connections
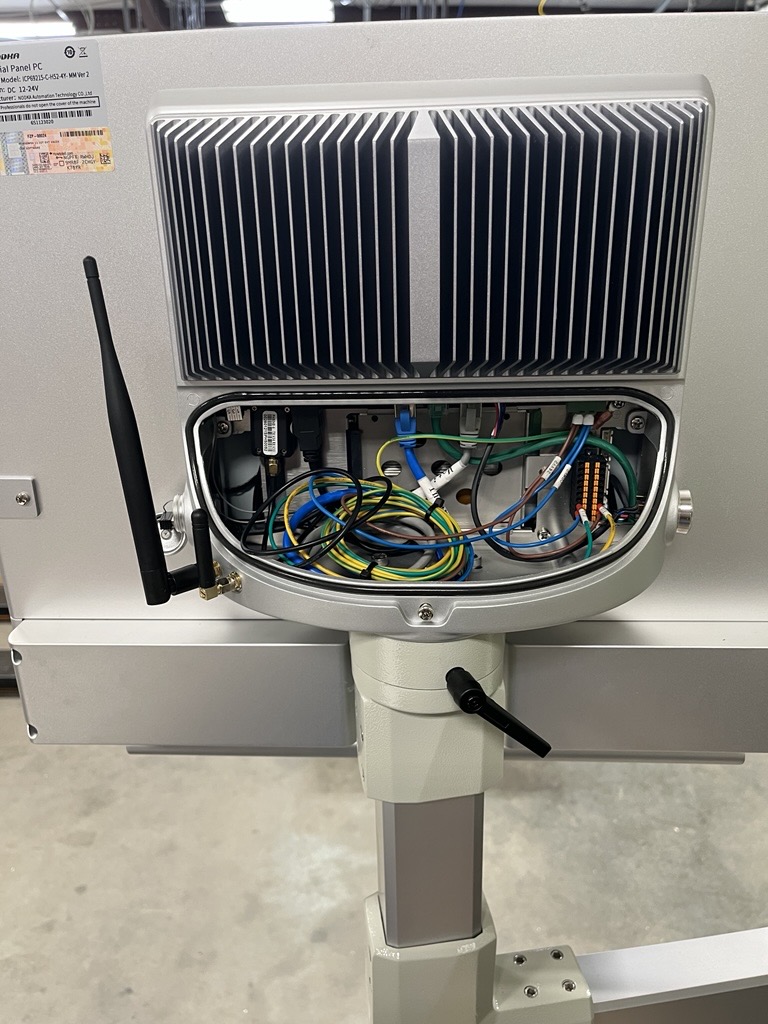
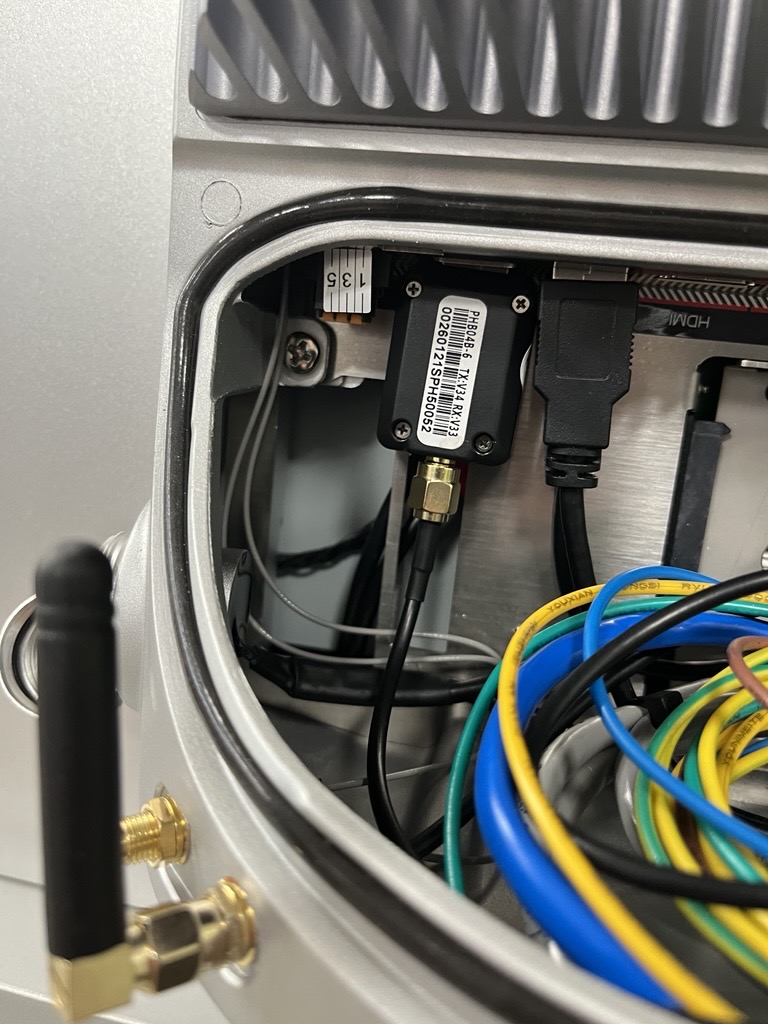
Replace the right antennae connector with the wireless pendant connector.
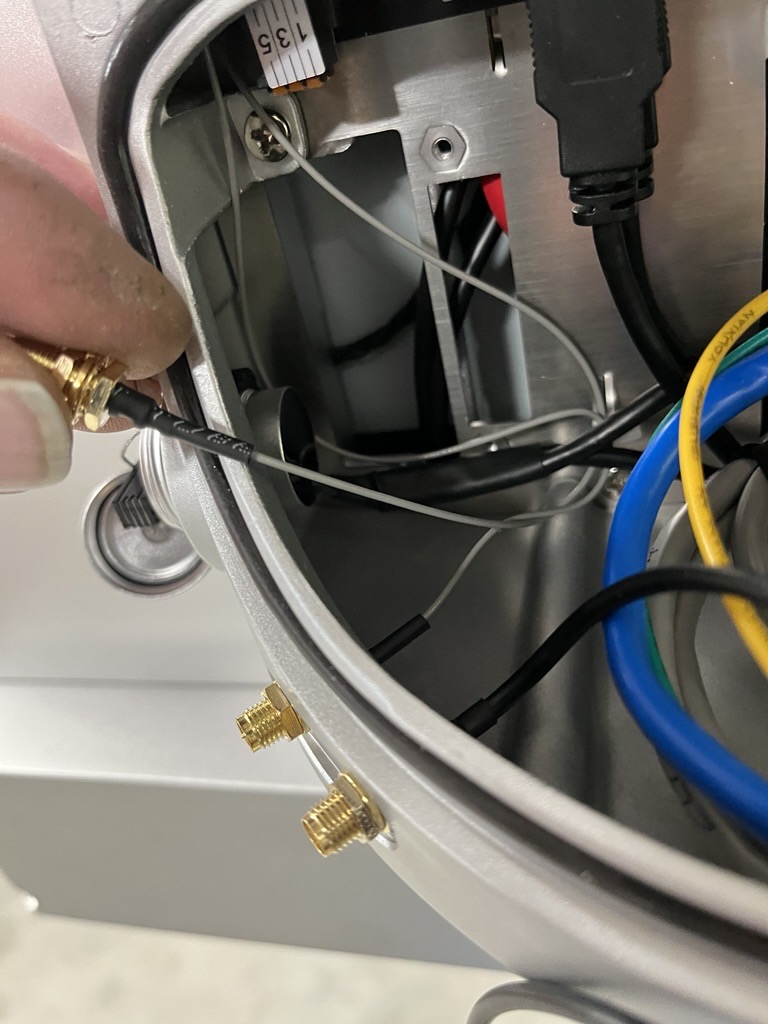
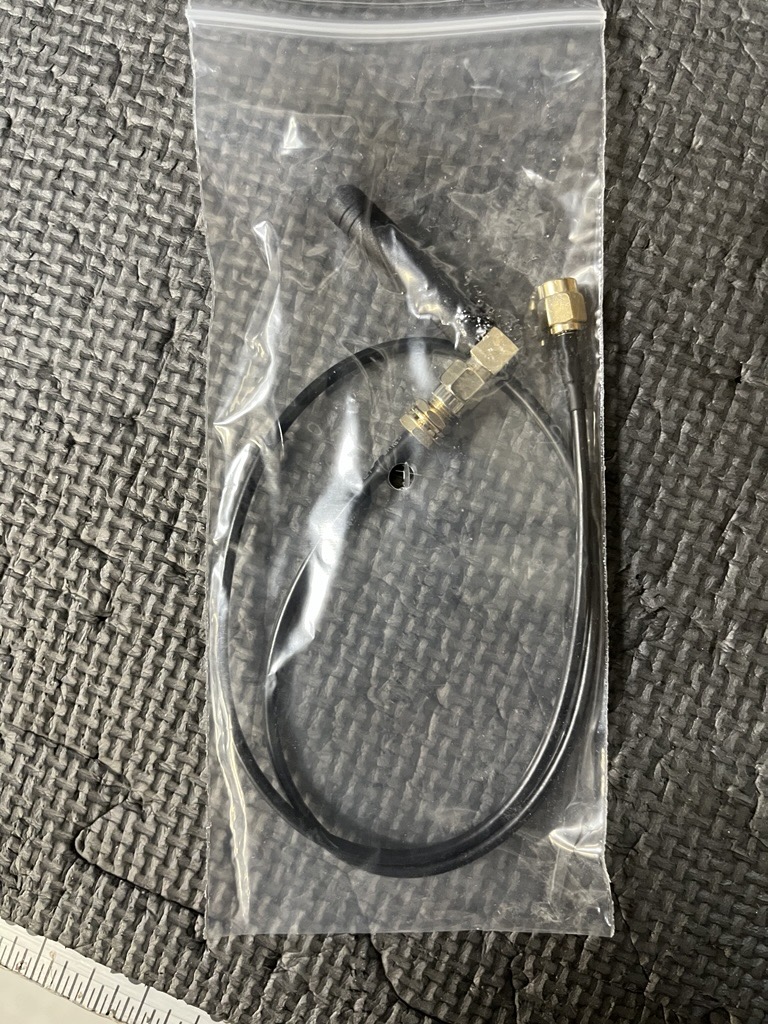
Plug the wireless pendant USB connector into the back USB and connect the cable between the two. Connect the antennae. Connect the Wifi antennae to the other screw connector.
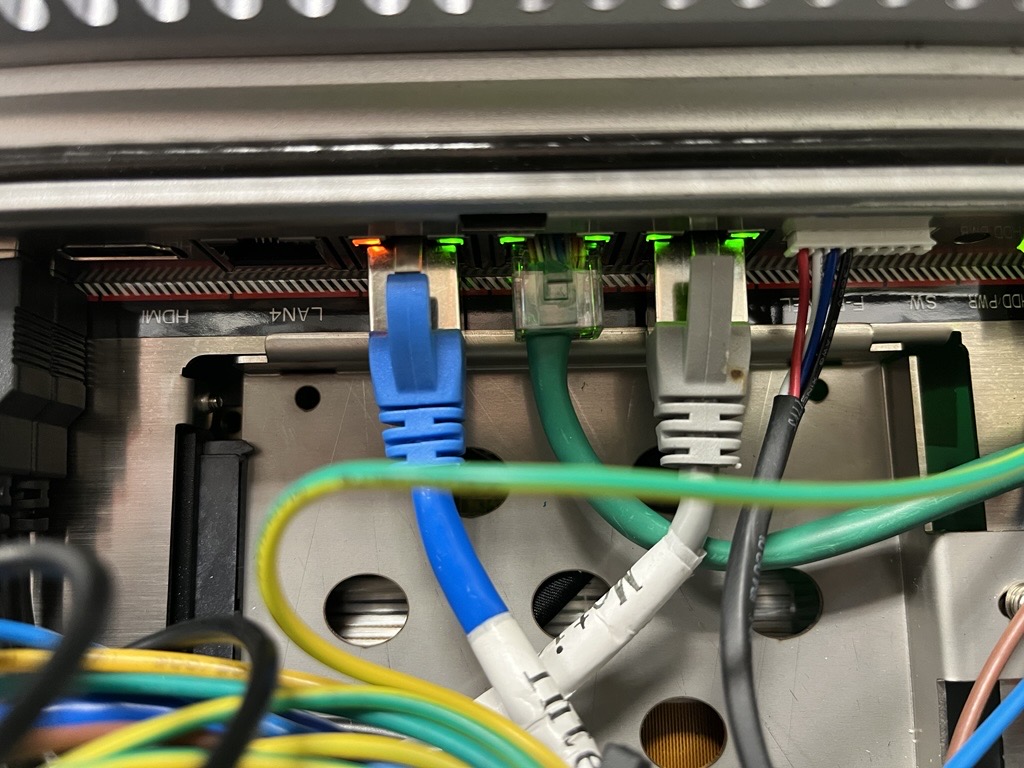
Connect the Internet cable to LAN3 and the Motion cable to LAN1.
Connect the ground wire to the ground location (upper right hand corner).
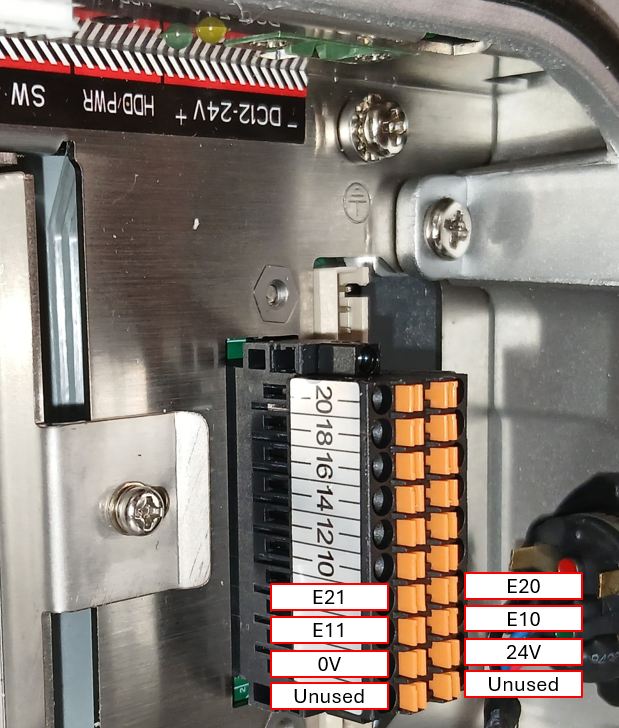
Double ferrule the incoming 24V and 0V with a small 6" jumper. Connect the double ferrule to the green plug and the jumpers to the block underneath accordingly. Connect the E10 and E11 wires to the same block accordingly. More than likely you will not have E20 and E21.
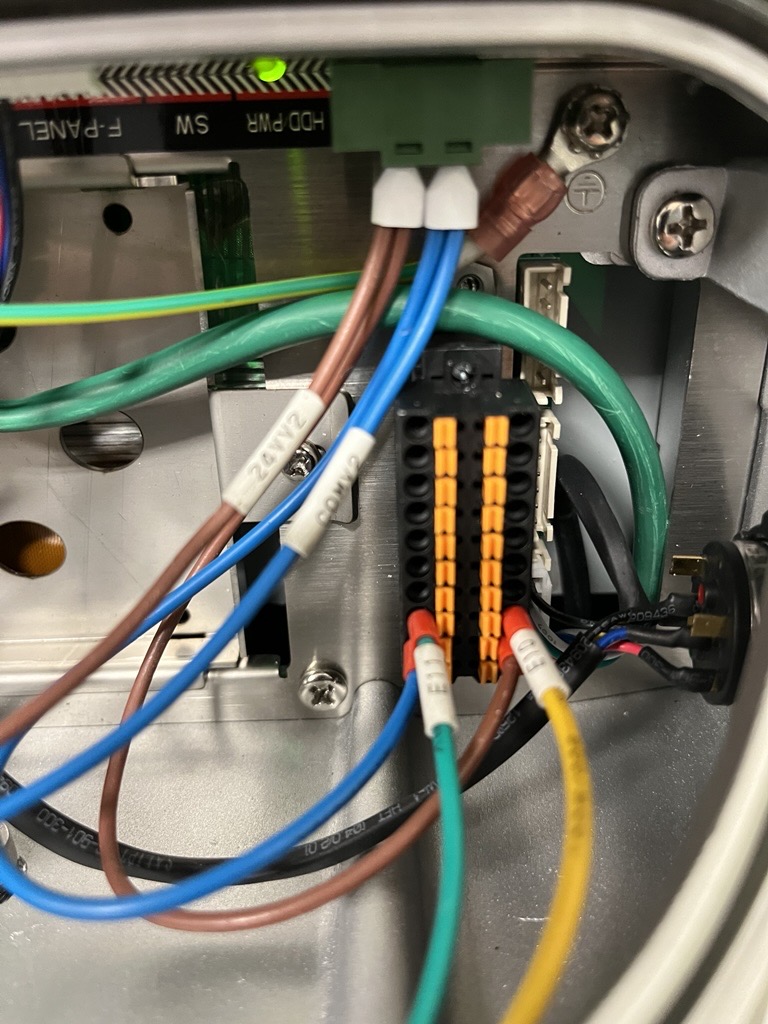
BEFORE POWER UP
Turn the main disconnect and all other breakers on the unit off and connect power. Check in-voltage for correctness (240V). Turn main disconnect to on and check in coming power to all circuit breakers for correctness (240V). Turn on all circuit breakers. Check the HMI power connections for correctness (24V)
SECTION 9 — SOFTWARE SETUP (HMI) Step 9.1 — Download Correct MachMotion Version
On the HMI:
-
Power on
- install machpro following the manual https://support.machmotion.com/link/1396
- Find latest tensile mill customer backup
Step 9.2 — Copy Machine Backup to USB
Copy newest backup onto USB → transfer to machine.
Step 9.3 — Rename Old Mach4 Folder
Rename existing folder:
-
Mach → Mach_old
Step 9.4 — Copy New Mach Folder
Paste new backup, rename folder to:
-
Mach (no spaces, no periods)
License Mach:
SECTION 10 — DRIVE SOFTWARE (VFD + SERVO) Step 10.1 — Install Required Software
The Drive software is not being installed on the control. The steps up to 10.6.2 will be done on a separate computer.
Install:
-
DCISoft 1.26 (for VFD)
- \\svr1.machmotion.local\MachMotion\Production\Products\Spindles\VFDs\Delta\MS300
- DELTA_IA-MDS_VFDSoft-V1-58_SW_20180725
- \\svr1.machmotion.local\MachMotion\Production\Products\Spindles\VFDs\Delta\MS300
- Leadshine software (for Servos) (witing the M Drive)
- \\svr1.machmotion.local\MachMotion\Production\Products\Drives-Servo\Leadshine\L7N
-
MotionStudio v2.3.2
Ensure computer/HMI has:
-
USB-B
-
USB-C (for Leadshine)
Step 10.2 — Set MotionStudio Language to English (Leadshine)
Open MotionStudio → Click language → select English → press Yes → restart.
Step 10.3 — Locate Correct MS300 Software Version
Use:
DELTA_IA-MDS_VFDSoft_V1-58_SW_20180725
10.4.1 — Install the Software
-
Locate the installer file.
-
Right-click and select Run as Administrator.
-
Install using all default settings.
-
When completed, launch the program.
10.5 — Connect to MS300 VFD
10.5.1 — Prepare the VFD
-
Power ON the machine.
-
Ensure the VFD is connected to the control PC via your USB-to-RS485/Modbus adapter.
10.5.2 — Detect the VFD in Software
-
Open MDS VFDSoft.
-
Click Scan.
-
Select the COM port the USB adapter uses.
-
Press Connect.
10.5.3 — Upload Correct Parameters
-
Load your saved MS300 configuration file (if provided).
-
Press Write to Drive.
-
Cycle power to the VFD.
10.6 — Install Servo Drive Software
The Yaskawa, Delta ASDA-B2, Leadshine, or other servo drives require their manufacturer configuration utility.
\\svr1.machmotion.local\MachMotion\Production\Products\Drives-Servo\Leadshine\L7N
Download the folder to your laptop and open the MotionStudio .exe file
10.6.1 — Install Servo Utility (Example: Delta ASDA-Soft)
-
Open installer.
-
Install with default settings.
-
Connect USB-RS232/USB-Mini cable to servo drive.
- Open Device Manager and confirm Active COM (1-10) port. (Connection will not be established without correct COM port)
-
Open the utility software.
10.6.2 — Load Drive Parameters (Leadshine)
-
Identify each drive (X, Y, Z).
- Open the File tab on the MotionStudio overhead toolbar, then select Download Parameter Files.
-
Load the correct
.prmfile or factory configuration, currently Basic_EtherCAT_Parameters.lsr, which is included in the L7N folder. -
Write parameters to the drive. If a pop-up window asks if you would like to still write abnormal parameter changes, select the left button, which means "Confirm the issuance" in Chinese.
- Verify the parameters have updated by opening the Parameter List from the menu on the left in MotionStudio. All of the updated parameter values should be highlighted in red.
- Reopen the Connect tab on the top toolbar and click the Disconnect button.
-
Reboot the servo drive, either by power cycling manually or simply by removing the USB C cable if updating the parameters with the panel turned off.
- Move the USB C cable to the next drive and repeat this process.
10.7.1 — Open VSI Device Manager
{{@1928#bkmrk-1.8-software-startup}}
-
Go to:
C:\Mach4Hobby\VSI Device Manager -
Launch VSI Device Manager.
-
Click Scan in the top-left.
10.7.2 — Select the Controller
After scanning, you should see a device with the following IP:
192.168.208.35
(This is the MachMotion M31 control board.)
-
Click to highlight 192.168.208.35.
-
Verify that the device information loads in the lower panel.
10.7.3 — Enter Loader Mode
In the lower panel of VSI Device Manager:
-
Click “Load Mode”
(sometimes labeled Boot Mode, Loader Mode, or Load Boot File Mode depending on software version)
The M31 will switch into loader mode, allowing firmware changes.
10.7.4 — Update the FPGA
-
Click Fast FPGA (button in lower panel).
-
Browse to the most up-to-date FPGA file provided by MachMotion.
(File extension is usually .rbf) -
Click Open / Write to begin flashing the FPGA.
-
Reboot the controller when prompted.
10.7.5 — Update the Firmware
After reboot:
-
Click Firmware Update (or Load Firmware File).
(Button is in the same lower panel as the FPGA option.) -
Browse to the latest firmware file (.bin). (in the mach/ motion controllers/ M31) file look for the latest Firmware.
-
Click Write to flash firmware.
-
Wait for confirmation.
-
Reboot the controller again.
10.7.6 — Finalize
-
Close VSI Device Manager.
-
Power cycle the entire machine:
-
Turn OFF main power
-
Wait 10 seconds
-
Turn power ON again
-
This ensures the M31 loads the new firmware and FPGA.
Load EtherCat Configuration. Loading EtherCat Configuration
10.8 — Verify EtherCAT & Controller Status in Mach4
After updating the FPGA and Firmware and power cycling the machine, you must confirm that Mach4 recognizes the controller and all EtherCAT devices correctly.
10.8.1 — Launch Mach
Open Mach4 normally from the HMI.
Wait for the main screen to finish loading.
10.8.2 — Check M31 Status
Open:
Diagnostics → M31 Status Panel
Verify: go to mach ( configuration/plugin/m31/ethercat/) after verifying upload refresh network ensure all devices are there then update - Okay - apply and restart mach software
-
Controller: Connected
-
Firmware Version: Updated
-
FPGA Version: Updated
-
EtherCAT: Running
-
Axis Drives: Enabled / Idle
-
No Faults or Lost Steps warnings
If anything shows red or Not Connected, power-cycle again.
10.8.3 — Check EtherCAT Devices
Open:
Diagnostics → EtherCAT
You should see:
-
M31 Controller
-
X-Axis Servo Drive
-
Y-Axis Servo Drive
-
Z-Axis Servo Drive
-
Any additional EtherCAT devices (IO blocks, tool setter blocks, etc.)
All devices should show:
-
Status: OK / Operational
-
Heartbeat: Active
If any drive is offline, check:
-
EtherCAT cable connections
-
Drive power
-
Termination (if required)
-
Drive alarms
10.8.4 — Verify Physical pokeys and Inputs/Outputs
Open mach motion go to Pokeys by going to (configuration/plugins/machmotion.com)
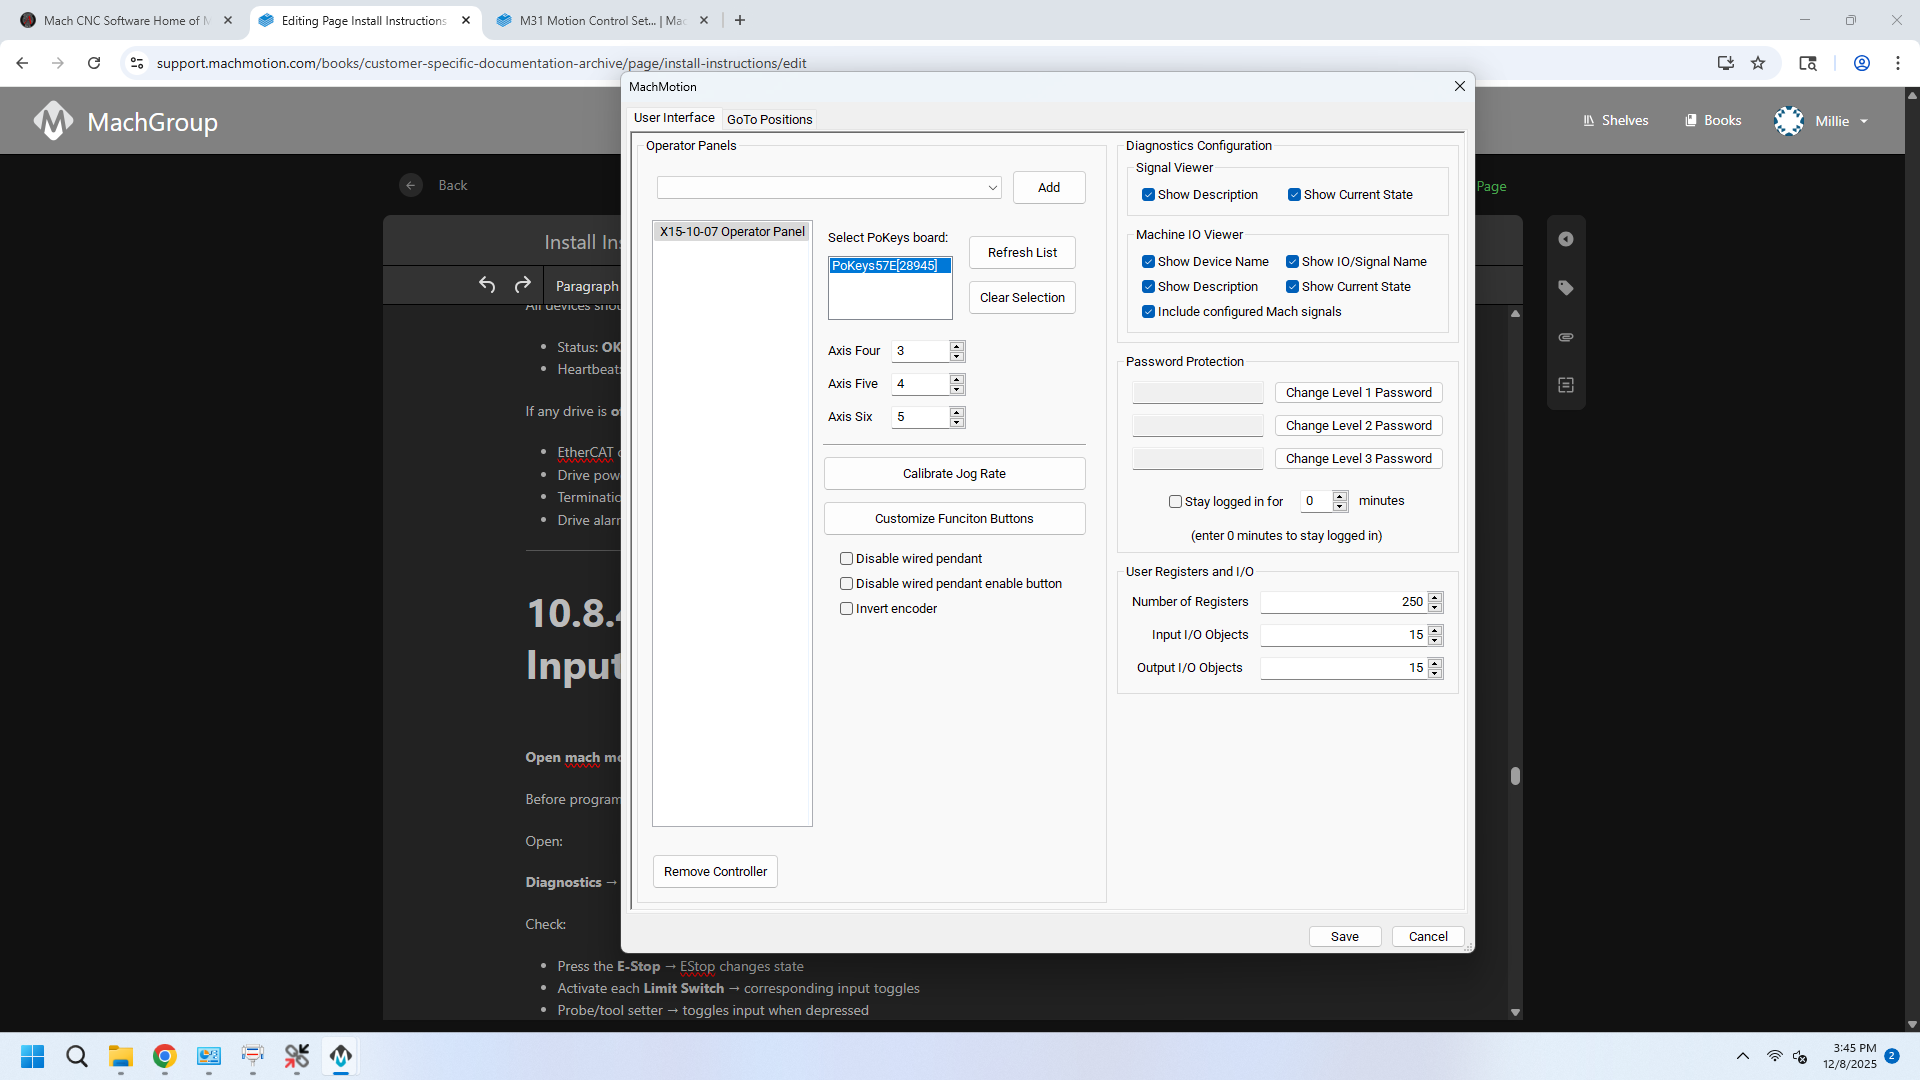
on this screen hit refresh list and then save
Before programming IO in Mach4, confirm that the hardware physically works.
Open:
Diagnostics → M31 I/O Monitor
Check:
-
Press the E-Stop → EStop changes state
-
Activate each Limit Switch → corresponding input toggles
-
Probe/tool setter → toggles input when depressed
-
Turn ON outputs manually (if toggling allowed) → coolant relay clicks / output LED activates
This proves the board and wiring are correctly connected before configuring Mach4.
10.9 — Program Inputs in Mach4 (Correct Method)
Now that inputs are verified, configure them in Mach4’s control system.
10.9.1 — Open the Control Configuration
Click the Input Signals tab.
10.9.2 — Assign Each Machine Input
For each input:
-
Check Enabled
-
Device should be set to M31
-
Set the correct Input Number (0–7 depending on J1 terminal)
-
Set Active Low if your switch is wired Normally Closed (NC)
Recommended Mapping (Based on Your Wiring):
| Function | Mach4 Signal Name | M31 Input # | Physical Terminal |
|---|---|---|---|
| X Limit | X-- | 0 | J1-00 |
| Y Limit | Y-- | 1 | J1-01 |
| Z Limit | Z-- | 2 | J1-02 |
| Probe | Probe Input | As wired | J1-xx |
| E-Stop | EStop | ESTP input | J6 |
10.9.3 — Save Inputs
Click OK, then restart Mach4 when prompted.
10.10 — Program Outputs in Mach4
Now configure coolant, spindle enable, and any auxiliary outputs.
10.10.1 — Open Output Signals
10.10.2 — Assign Outputs
For each output:
-
Enable the output
-
Set Device to M31
-
Assign Output # (0–7 depending on J10 terminals)
Your Likely Output Mapping:
| Function | Mach4 Output | M31 Output # | Terminal |
|---|---|---|---|
| Coolant Pump | Flood | 0 | J10-00 |
| Mist (optional) | Mist | 1 | J10-01 |
| Spindle Enable | SpindleOn | 2 | J5 or J10-02 |
| PWM Spindle/Laser | PWM | J7 PWM pin | J7 |
If a relay behaves backward, toggle Active Low.
10.10.3 — Save Outputs
Click OK
Restart Mach4.
10.11 — Configure Homing & Soft Limits
Homing MUST be set up before calibrating the machine.
10.11.1 — Open Homing Settings
Mach4 → Configure → Control → Homing/Soft Limits
10.11.2 — Assign Homing Order
Recommended order for a tensile mill:
-
Z Axis — Home Order 1
-
X Axis — Home Order 2
-
Y Axis — Home Order 3
10.11.3 — Set Homing Directions
Based on typical tensile mill design:
-
Z homes Positive (UP)
-
X homes Negative
-
Y homes Negative
Reverse direction in Motor Config if needed.
10.11.4 — Test Homing
Click Ref All Home
Verify:
-
Z raises to switch
-
X moves to its limit
-
Y moves to its limit
-
No axis crashes or moves opposite
If incorrect direction:
Mach4 → Configure → Control → Motors → check Invert Motion
10.12 — Axis Calibration (from Your PDF)
Based on “mach4-axis-motor-calibration.pdf”
Mach4 supports Manual and Automatic axis calibration.
10.12.1 — Open Calibration Tool
Mach4 → Configure → Plugins → Machine Calibration
Choose Manual Calibration or Automatic Calibration.
Manual Calibration Procedure (Recommended for Precision)
10.12.2 — Manual Calibration Steps
-
Select the axis (X/Y/Z).
-
Enter a commanded distance (e.g., 2.0000 inches).
-
Click Enable.
-
Click Move.
-
Measure actual travel using:
-
Dial indicator
-
Caliper
-
Gauge block
-
-
Enter the actual distance traveled.
-
Click Submit — Mach4 calculates new Steps Per Unit.
-
Click Accept.
Repeat for each axis.
Automatic Calibration Procedure
10.12.3 — Automatic Method
Enter:
-
Motor model
-
Gear ratio
-
Ball screw pitch
-
Microstep setting
Mach4 calculates theoretical values and loads them.
Fine-tune afterward with manual calibration.
10.13 — Final Machine Validation Checklist
Before running production or test cycles, verify:
10.13.1 Mechanical
✔ All axes home correctly
✔ No binding or sticking
✔ Motors run smoothly
10.13.2 Electrical
✔ IO states correct
✔ Outputs activate correct devices
✔ All limits function
✔ E-stop functions every time
✔ No servo drive alarms
✔ VFD responds to Mach4 commands
10.13.3 Software
✔ EtherCAT online
✔ M31 connected with firmware/FPGA updated
✔ Correct Mach4 profile loaded
✔ Calibration accuracy within tolerance
✔ Soft limits verified
Password protection for CNC button and setup button. Set to Tensile123
Step 11- Mount and wire Tool Setter

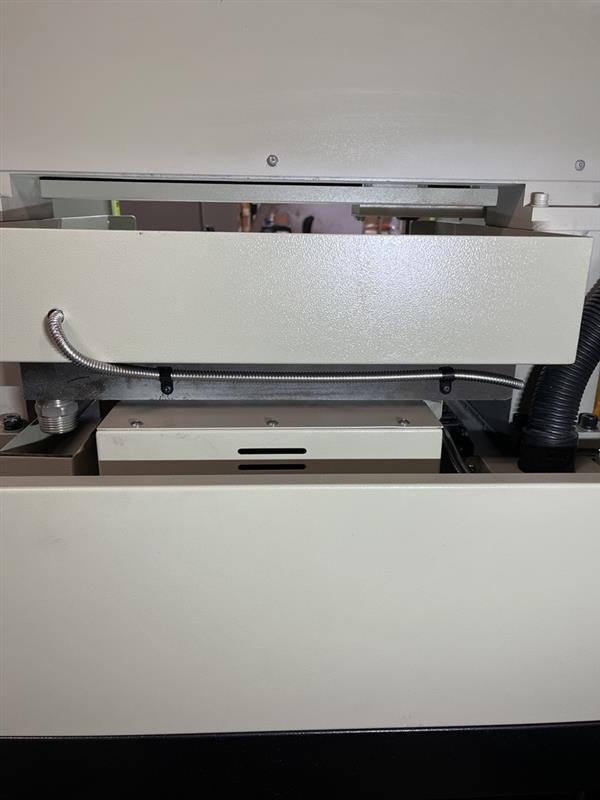
11.2- Run Tool Setter cable through the cable track

11.3- Run Tool Setter Cable out of the cable track and into the black loom, down into the cabinet

11.4- Wire the Tool Setter into the M31
Orange Wire- Tool Setter Touch- Label 6114- J1 Port 5
Blue Wire- Tool Setter Limit- Label 6116- J1 Port 6
Green Wire- 24VDC+ Common- Label 6115- J2 Port 2
Brown Wire- 24VDC+ Common- Label 6113- J2 Port 3
Red Wire- 24VDC+ Common- Label 6112- J2 Port 4
Grey Wire- 0VDC- Common- Label 0V- J11 Port 1
